 AI-generated setting
Receiving to storage
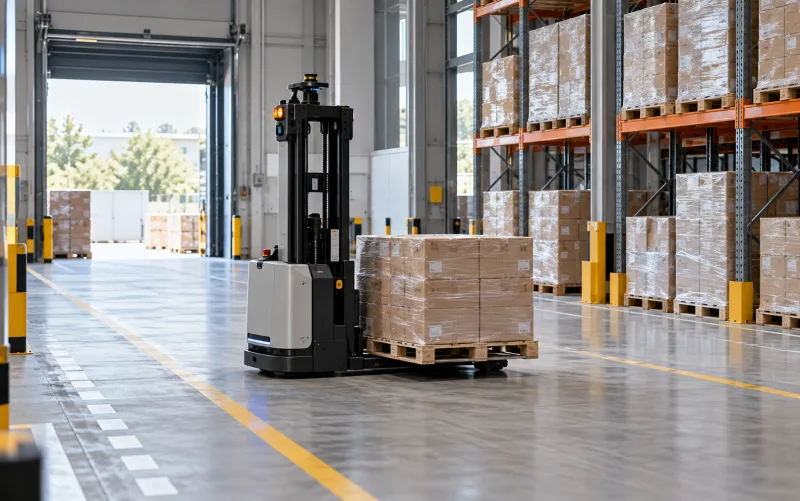
Move checked pallets to defined buffer positions, with staff inspecting goods and pallet condition before release.
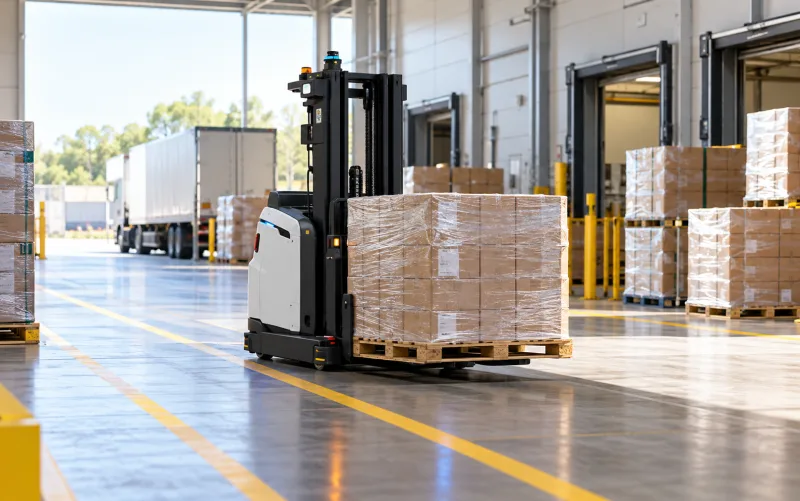
Design pallet pickup, lifting and delivery between storage and production around real pallets, transfer heights and site traffic.
Define the duty cycle and handover points before choosing equipment. The robot works with your team and the site’s existing processes.
AI-generated settingMove checked pallets to defined buffer positions, with staff inspecting goods and pallet condition before release.
 AI-generated setting
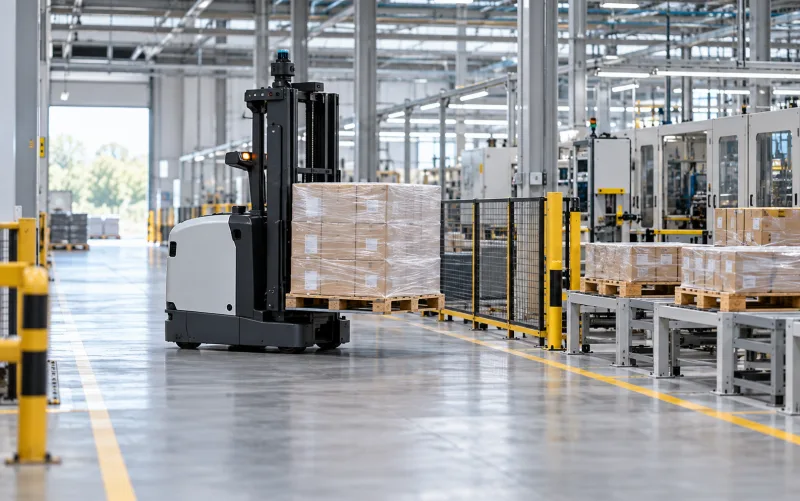
Define material pickup and line-side drop-off, separating waiting loads from through traffic.
 AI-generated setting
Queue finished pallets for inspection or dispatch buffers according to destination readiness.
Model references support assessment, rather than establish stock or a quotation. Confirm the variant, latest documentation and support scope before specification.
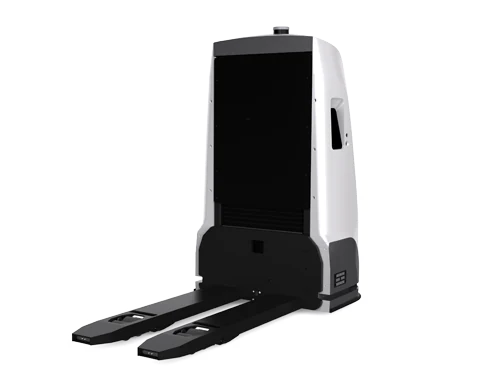
An automatic forklift reference listed by Sun Robot for pallet work. Use it to assess floor-level handovers before selecting the final configuration.
An original manufacturer datasheet for the exact variant has not been established; supplier overview figures are not published here as verified capacity, clearance or lift-height specifications.
Select a stage to see how preparation, robot movement and handover fit together. This is an operating concept, not a surveyed map or a capability shared by every model.
Route concept · stops, protected areas and charging are designed around the selected model and site.
Staff inspect pallet condition, overhang and pickup position before releasing an operator or host-system job.
Equipment is one part of the system. Handover points, operating responsibilities and site conditions must be prepared together.
Record dimensions, fork pockets, material, pallet condition, weight and centre of gravity. Include damaged pallets and overhanging loads in the assessment.
Measure turns, doors, slopes, floor joints and transfer heights. Assess mixed pedestrian/forklift traffic and define traffic separation.
Choose operator or host-system calls. Define waiting/recovery for blocked routes, misplaced pallets and network loss, with authorised recovery staff.
A project delivery sequence, not a wiring or machine-configuration manual. Installation and risk assessment require the applicable equipment instructions and qualified personnel.
Agree loads, endpoints, operating windows and responsibilities. Define task-cycle and exception criteria before selecting equipment.
Assess representative pallets, loads, handovers and floors; record pedestrian and vehicle crossings.
Specify handovers, waiting points, charging, exclusion zones and job calls. Scope doors, lifts, networking and software interfaces explicitly.
Prepare floors, aisles, power and networking for the selected equipment. Qualified installers handle site services; then map the site, assign permissions and configure stations.
Trial repeated pickup/drop-off, varying loads, blocked paths, misplaced pallets and emergency stopping under an agreed test plan.
Train task start/stop, loading, charging and recovery using the equipment instructions. Hand over layouts, routes, settings, trial results and maintenance arrangements.
Define equipment, attachments, software, interfaces, training, maintenance and support in the proposal. Pricing and contract terms depend on the project.
Compare a people-led workflow with a team supported by robots, and estimate simple payback. Adjust the inputs to your work scope and quotation.
Starting figures are an illustrative cleaning scenario, not selling prices, rental rates or guaranteed returns. Compare equivalent coverage, duty cycles and service quality.
Estimated simple payback
1.9 years
The point where cumulative costs meet. Beyond it, the difference is estimated cost savings.
| Year | People-led | Team + robot |
|---|---|---|
| 0 | 0 | 340,000 |
| 1 | 300,000 | 460,000 |
| 2 | 600,000 | 580,000 |
| 3 | 900,000 | 700,000 |
| 4 | 1,200,000 | 820,000 |
| 5 | 1,500,000 | 940,000 |
Monthly difference = current labor − (remaining labor + operation + rent when renting). Payback in years = deployment plus purchase, if applicable, ÷ monthly difference ÷ 12. Payback requires a positive monthly difference.
Count only genuinely avoidable labor spending. Redeploying staff does not automatically reduce payroll. These are cost savings, not accounting profit. Tax, financing, inflation, resale and the time value of money are excluded. Monthly costs are assumed constant over the selected period.
Check fork pockets, material, size, condition and the actual load, then trial them. Pallet shape names alone do not establish compatibility.
Assess crossings, stopping, visibility, right-of-way and separation, then train staff for the selected system.
Specify the model, interface, API access, job data and recovery behavior. Integration is scoped and tested separately from the robot hardware.
Reviewed 31 October 2026. Details can differ by variant, region and configuration; reconfirm them in the project proposal.